The final program is available below an d in PDF format HERE.
Sessions Day I - 9th July
|
Time |
Session |
Authors |
|
08:00 - 08:45 |
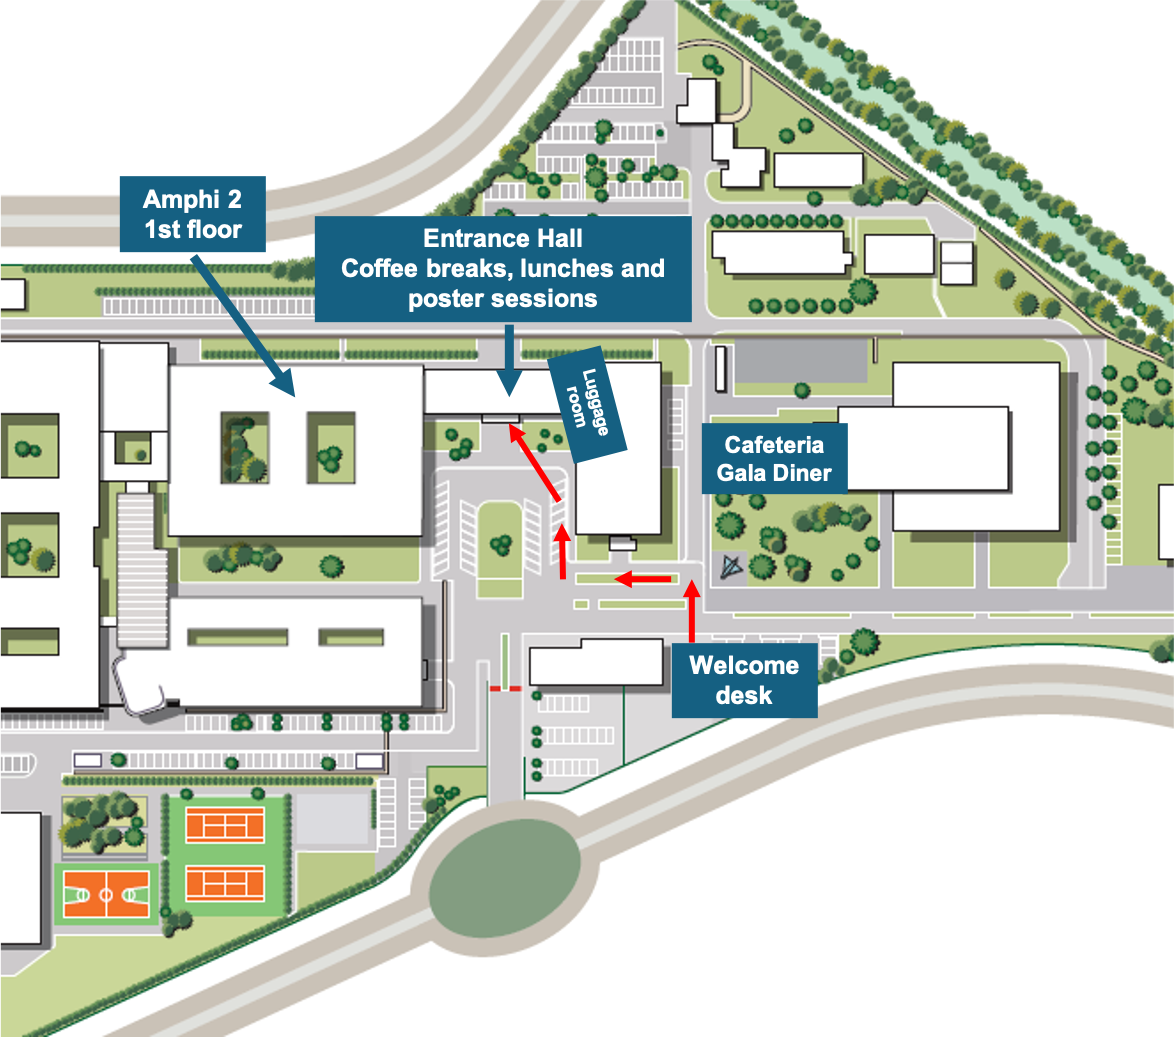
Registration - Entrance Hall |
|
|
08:45 - 09:00 |
Opening - Amphi 2 |
|
|
09:00 - 09:45 |
KEYNOTE I - Amphi 2 |
|
|
09:45 - 10:15 |
COFFEE BREAK + POSTERS (PITCHES) - Entrance Hall |
|
|
10:15 - 11:10 |
T1.1 - Recent Real-World Space Mission GNC V&V experiences - Amphi 2 |
|
|
|
Validation approach for a rendezvous GNC bi-compatible with Vision and LIDAR sensing |
Vincent DUBANCHET (TAS); Romain MORA (TAS); Davide CASU (TAS); Angelo AUSIELLO (TAS) |
|
Reusable V&V methodology for GNC algorithms with application to EARS satellite re-entry |
Adolfo Molina Delgado (DEIMOS); Giuseppe Edoardo Addario (DEIMOS); Giovanni Medici (DEIMOS); |
|
|
Validation of Guidance, Navigation & Control on-board architecture for Mars Sample Return Rendezvous |
Alexandre Falcoz (Airbus DS); Benjamin Charbaut (Airbus DS); Marc Jacquiau (Airbus DS); Keyvan Kanani (Airbus DS); |
|
|
LISA DFACS Robustness Analysis |
Martin Maurice (Airbus DS) |
|
|
11:10 - 12:00 |
T9 - Hardware-based V&V - Amphi 2 |
|
|
|
Validation & Verification of Vision-based Navigation Algorithms via Geometric- and Radiometric-Consistent Optical Stimulators |
Paolo Panicucci (POLIMI); Fabio Ornati (POLIMI); Andrea Pizzetti (POLIMI); Francesco Topputo (POLIMI) |
|
Streamlining Laboratory Dataset Generation for Training and Verification of Vision Based Navigation in Space |
Sebastian Rimmer (ESA); Ane Morkemo (ESA); Joris Belhadj (ESA); Irene Huertas Garcia (ESA); Djordje Lepir (ESA) |
|
|
Hardware-in-the-Loop Testbeds for Attitude Control in Distributed Networks Composed of Small Satellites |
Timon Petermann (ZfT); Lisa Elsner (ZfT); Klaus Schilling (ZfT) |
|
|
V&V of Autonomous Spacecraft Proximity Maneuvers Leveraging HIL Lab Facilities: Standardization & Benchmark Problems |
Marcello Romano (TUM) |
|
|
12:00 - 13:30 |
LUNCH BREAK + POSTERS (PITCHES) - Entrance Hall |
|
|
13:30 - 14:40 |
T3 - Bridging the Research-Industrial Gap - Amphi 2 |
|
|
|
Framework for Systematic Control Design and Verification in Drag-Free Missions |
Francesco Basile (TAS); Carlo Novara (POLITO); Vinicius Marchioli (POLITO); Mattia Boggio (POLITO); Michele Pagone (POLITO) |
|
On-board Safety Filters for Thrust Vector Control of Launchers |
Aitor Gomez (Aalborg University); João Belfo (DEIMOS); Jose Vasconcelos (DEIMOS); Pedro Simplicio (ESA); |
|
|
Developing tools to improve efficiency and reliability of GNC design and V&V: from research to industry |
Ervan Kassarian (DYCSYT); Francesco Sanfedino (ISAE-SUPAERO); Daniel Alazard (ISAE-SUPAERO); Andrea Marrazza (DYCSYT) |
|
|
Closed-loop CFD simulator for fuel sloshing mitigation V&V |
Michael Fogel (Rutgers University); Laurent Burlion (Rutgers University) |
|
|
Probabilistic Robust Performance based on Linear Fractional Transformations and Polynomial Chaos Expansion |
Harald Pfifer (TU Dresden); Mario Izquierdo Serra (Airbus DS); Maurice Martin (Airbus DS); Stefan Winkler (Airbus DS) |
|
|
14:40 - 15:10 |
The European Pointing Benchmark Problem - Amphi 2 |
|
|
15:10 - 15:40 |
COFFEE BREAK + POSTERS (PITCHES) - Entrance Hall |
|
|
15:40 - 16:30 |
T5 - V&V Research in Academia - Amphi 2 |
|
|
|
Advancements in Autonomous Space Robotics at Onera : Control Frameworks and Co-Design Strategies for On-Orbit |
Sofiane Kraïem (ONERA); Mathieu Rognant (ONERA); Sérgio Waitman (ONERA) |
|
GNC V&V experiences from a LISA mission study |
Diego Navarro-Tapia (UC3M); Andres Marcos (UC3M) |
|
|
Verifying the implementation of optimization algorithms via Integral Quadratic Constraints |
Alexandre Chapoutot (ENSTA); Pierre-loic Garoche (ENAC) |
|
|
OvertPoly: An Algorithm for Scalable and Precise Verification of Nonlinear Neural Feedback Systems |
Samuel Akinwande (Stanford University); Chelsea Sidrane (KTH); |
|
|
16:30 - 17:00 |
V&V of Adaptive Augmenting Control System Flown on NASA’s Space Launch System for Artemis I |
|
|
17:00 - 18:00 |
BREAK |
|
|
18:00 - 21:00 |
COCKTAIL DINNER + T8 - Poster session for Innovatve Research in GNC/V&V - Cafeteria |
|
|
|
The CubeSat attitude V&V air bearing facility installed at ESA-ESTEC |
Andrea Curatolo (Università di Bologna) |
|
Towards a Verifiable Linear Programming-based SCVx Algorithm |
Danil Berrah (ENSTA); Damien Hoareau (ENSTA); Alexandre Chapoutot (ENSTA) |
|
|
Formal verification of artificial intelligence in guidance, navigation and control systems |
Céline Bellanger (ENAC); Pierre-Loïc Garoche (ENAC); Matthieu Martel (Université de Perpignan); Célia Picard (ENAC) |
|
|
Gaussian process-based grid point allocation for robust control |
E. Javier Olucha (Eindhoven University of Technology); Valentin Preda (ESA); Amritam Das Eindhoven (University of Technology); |
|
|
Methodologies, algorithms and processes for the development of Thrust Vector Control for aerospace applications |
Luca Palombi (AVIO) |
|
|
Collision avoidance maneuver computation and validation for long-term space encounters |
Matthieu Masson (LAAS-CNRS) ; Christian Artigues (LAAS-CNRS) ; Denis Arzelier (LAAS-CNRS) ; Fabrizio Dabbene (CNR-IEITT); |
|
|
A Bottom-Up Approach for Radiometric Validation of Synthetic Imagery |
Andrea Pizzetti (POLIMI); Paolo Panicucci (POLIMI); Francesco Topputo (POLIMI) |
|
|
Modular Attitude Determination and Control System Approaches for a Broad Range of Nano-Satellites |
Lisa Elsner (ZfT); Vijay Nagalingesh (ZfT); Klaus Schilling (ZfT) |
|
|
Certifying Quantized Neural Networks for Autonomous Control -- a Robustness-based Approach |
Wahiba Bachiri (Abou Bakr Belkaid university); Pierre-loic Garoche (ENAC); Yassamine Seladji (Abou Bakr Belkaid university) |
|
|
Counter Optimization: Worst-Case Optimization for Validation and Verification of Complex Black-Box Systems |
David Braun (TUM); Patrick Piprek (ESA); Florian Holzapfel (TUM) |
|
|
LFT Modeling of closed kinematic chains |
José Afonso de Oliveira Moreno Neves (ISAE-SUPAERO); Francesco Sanfedino (ISAE-SUPAERO); Daniel Alazard (ISAE-SUPAERO) |
|
|
Robustness Guarantees for Nonlinear Trajectory Planning Applied to Orbital Robots Tasks |
Caroline Specht (DLR) |
|
|
Pyxis: A higly predictable toolchain for FPGA circuit production of advanced GNC algorithm |
Inès Winandy (ENAC); Arnaud Dion (ISAE-SUPAERO); Pierre-Loïc Garoche (ENAC); Florent Manni (CNES) |
|
Session Day 2 - 10th July
|
Time |
Session |
Authors |
|
08:00 - 08:45 |
Registration - Entrance Hall |
|
|
08:45 - 09:00 |
Opening - Amphi 2 |
|
|
09:00 - 09:45 |
KEYNOTE II - Amphi 2 |
|
|
09:45 - 10:15 |
COFFEE BREAK + POSTERS (PITCHES) - Entrance Hall |
|
|
10:15 - 11:25 |
T2.1 - Efficient V&V Tools and Methodologies for Systems Using Modern GNC Technologies - Amphi 2 |
|
|
|
GNC Flight Software Development and Verification: A process, its evolution, and the challenges involved. |
Leonardo Borges Farconi (DLR) |
|
Feasible and safe CONOPS analyses for Close Proximity Operations - Use-case of EROSS project |
Vincent DUBANCHET (TAS); Romain MORA (TAS); Davide CASU (TAS); Angelo AUSIELLO (TAS) |
|
|
Combining Sensitivity and Robustness Analyses for AOCS Verification and Validation |
Maurice Martin (Airbus DS) |
|
|
Validation of the DLR Crater Navigation System for Autonomous Precise Lunar Landing |
Eleonora Andreis (DLR); Hans Krüger; Stephan Theil (DLR) |
|
|
GPU accelerated and differentiable simulators for modern GNC engineering |
Valentin Preda (ESA) |
|
|
11:25 - 12:30 |
T2.2 - Efficient V&V Tools and Methodologies for Systems Using Modern GNC Technologies - Amphi 2 |
|
|
|
Conservative and compliant Monte-Carlo simulation campaigns by design |
Nicolas Deslaef (ESA); Francois Benoit du Rey (ESA) |
|
IQClab: An IQC based toolbox for robustness analysis and control design - updates and new features |
Joost Veenman (Novantec) |
|
|
Validation of Autonomous Orbit Control of a swarm in a system simulator |
Cécile DECHOZ (CNES); Irene Valenzuela Molina (CNES); Marie-Claire CHARMEAU (CNES); Bernard PONTET (CNES); Julien GALIZZI (CNES); Yoan GREGOIRE (CNES); |
|
|
Verification and Validation of Fault Detection and Diagnosis algorithms for launch vehicle TVC systems |
Stefano Farì (DLR); David Seelbinder (DLR); Stephan Theil (DLR); Pedro Simplicio (ESA) |
|
|
Robust H2-Norm Analysis of Uncertain Space Systems |
Tommaso Casati (ONERA) |
|
|
12:30 - 14:00 |
LUNCH BREAK + POSTERS (PITCHES) - Entrance Hall |
|
|
14:00 - 14:50 |
T7 - Non-Traditional Techniques for Conducting GNC Algorithm V&V for Non-Space Applications - Amphi 2 |
|
|
|
End-to-End Development and Validation of GNC Algorithms: Towards an Iterative and Automated Process |
Jose Luis Redondo Gutierrez (DLR); Ansgar Heidecker (DLR); Marco Sagliano (DLR); Andreas Wenzel (DLR); Leonardo Borges Farconi (DLR); Maces Hernandez Jose Alfredo (DLR); |
|
Leveraging robust control tools for code-level formal verification of GNC algorithms |
Elias Khalife (Virginia Tech); Mazen Farhood (Virginia Tech); Pierre-loic Garoche (ENAC) |
|
|
Bridging Non-Space V&V Practices to Enhance Space GNC Systems |
Stephan van Beek (MathWorks); Ossi Saarela (MathWorks); Jean-Paul Marcade (MathWorks) |
|
|
Verification, Validation and Safety Assessment of Machine Learning Airborne Applications |
Konstantin Dmitriev (MathWorks) |
|
|
14:50 - 15:20 |
T6 - New Space Alternative Approaches to the Traditional GNC V&V Process - Amphi 2 |
|
|
|
Experimental verification and validation of the CubeSpec mission high-precision pointing system |
Leonardo Peri (KU Leuven); Dirk Vandepitte (KU Leuven) |
|
Attitude Determination and Control System Development for Nanosats with Focus on Performance, Robustness and Reliability |
Mikel Samson (arcsec); Rhimas Van de Putte (arcsec); Wim De Munter (arcsec) |
|
|
15:20 - 15:50 |
COFFEE BREAK + POSTERS (PITCHES) - Entrance Hall |
|
|
15:50 - 16:30 |
WRAP UP - Amphi 2 |
|
Helpful instructions to prepare oral presentation and poster presentation
Pitch sessions + Posters helpful instructions
- The amphitheater is equipped with a computer and a projection system. To secure presentations, we already asked you to upload your slides in a dedicated section
For your oral presentation, you will use a PPT or PDF format, your slideshow will be necessary displayed with the conference computer (Windows)
Just in case, please, prepare and bring a USB flash drive with your presentation files.
Poster session
- Poster presentations linked to a pitch will be displayed in the entrance hall (the same area as the coffee breaks). Only posters corresponding to pitches scheduled for that day will be exhibited
- Poster session for Innovative Research in GNC/V&V will take place at the cafeteria (during the cocktail dinner)
- The dimensions of your poster should be A0, portrait orientation (841 x 1189 mm).
- Your poster includes a title, the author(s), affiliation(s), and a description of the research highlighting the major elements that are covered in the abstract.
- Make sur your lettering is neatly done and is large enough to be read from a distance.
- At your arrival at ISAE-SUPAERO, the welcome desk will provide you information of the location of the boards and give you magnets to hang your poster.
- Before leaving ISAE-SUPAERO, you must take your poster with you and return magnets to the welcome desk.
